Redefining the integration model: What is valuable busyness? (Part 2)
In Part 1 of this series, we explored the trap of "Reactive Busyness" and why leading system integrators are shifting toward...
Who will make money in Physical AI?
Billions of dollars are flowing into companies trying to build general-purpose intelligence for robots.
Redefining the integration model: What is valuable busyness? (Part 1)
What is "Valuable Busyness" for System Integrators? If you run or manage a robotics integration business, your engineering...
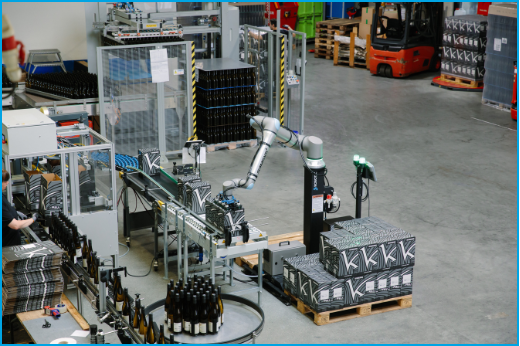
Palletizing Automation for Seasonal Peaks: 5 Lessons
How three manufacturers tackled seasonal peaks and cut their reliance on temporary workers with palletizing automation.
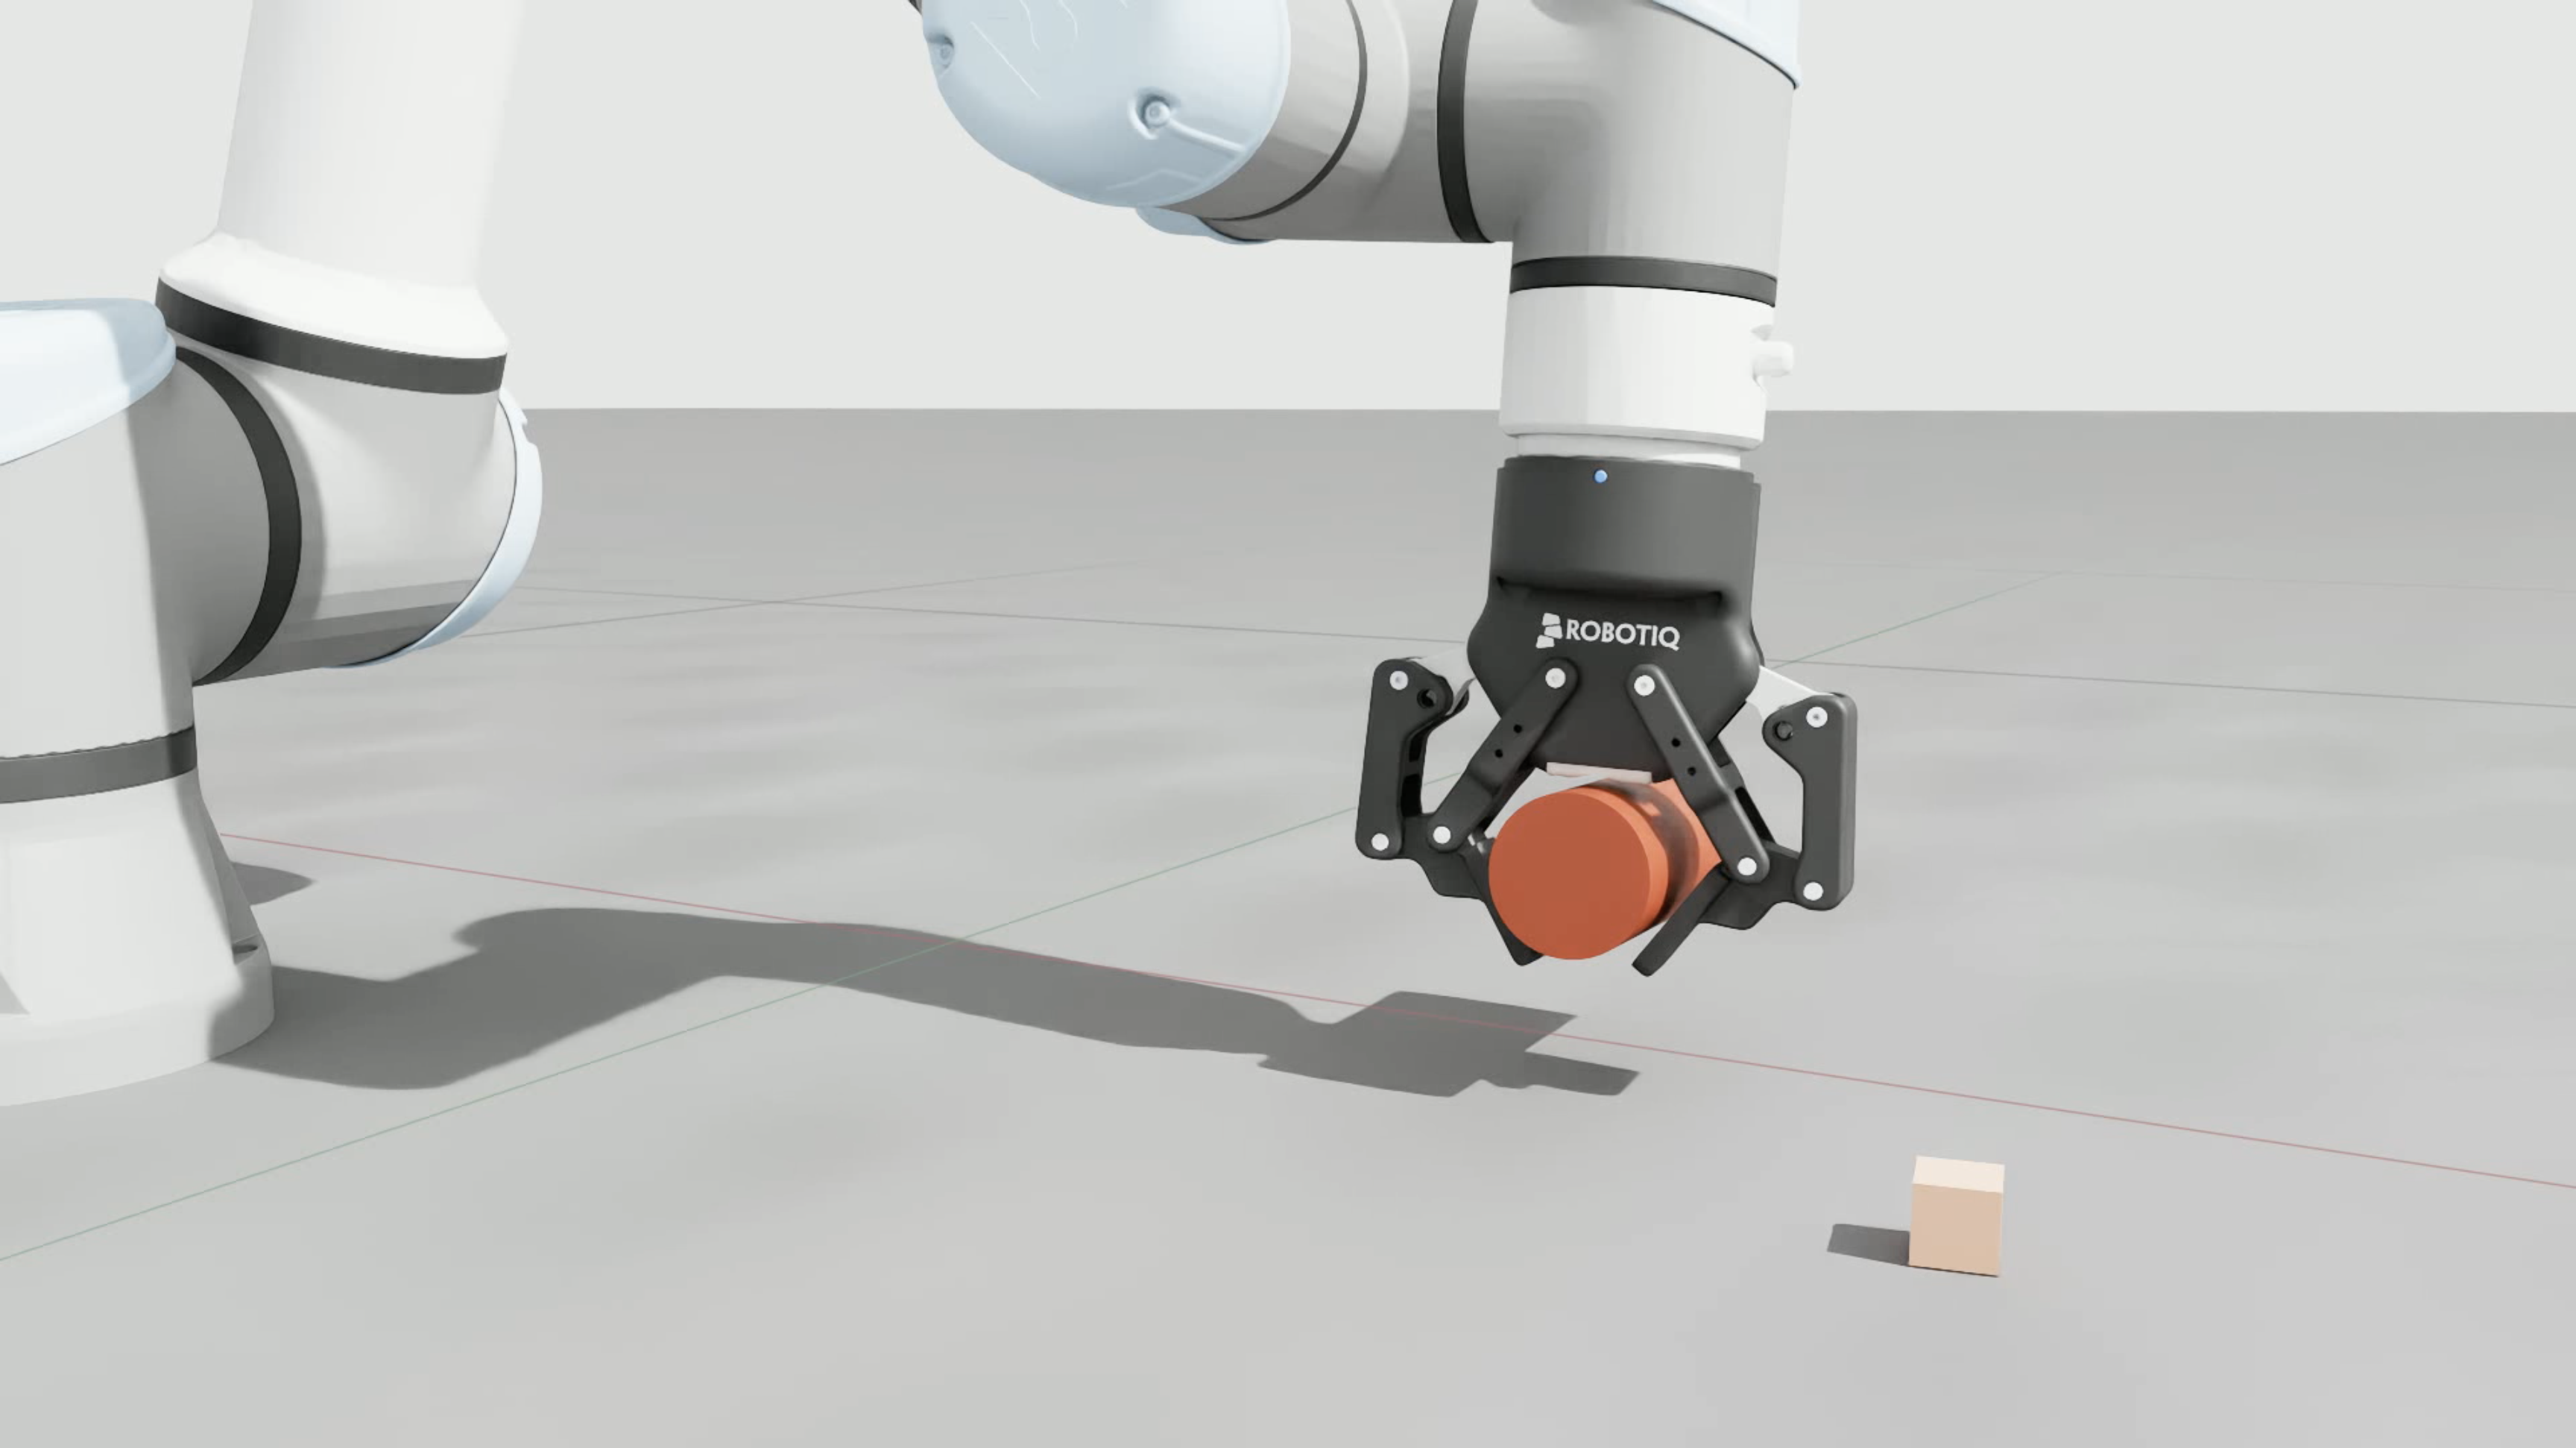
Robotiq Releases New 2F-85 Isaac Sim Asset on Newton
If you have put a Robotiq 2F-85 into an NVIDIA Isaac Sim scene and closed it on an object, you have probably seen the fingers...
Robotiq Releases ROS 2 Packages for Adaptive Grippers
If you run a Robotiq gripper in the Robot Operating System (ROS) 2 workspace today, you are almost certainly running PickNik...
Robotiq Releases an Open-Source C++ SDK for Adaptive Grippers
As physical AI moves from research into real applications, developers need a solid primitive that meets them where they work:...
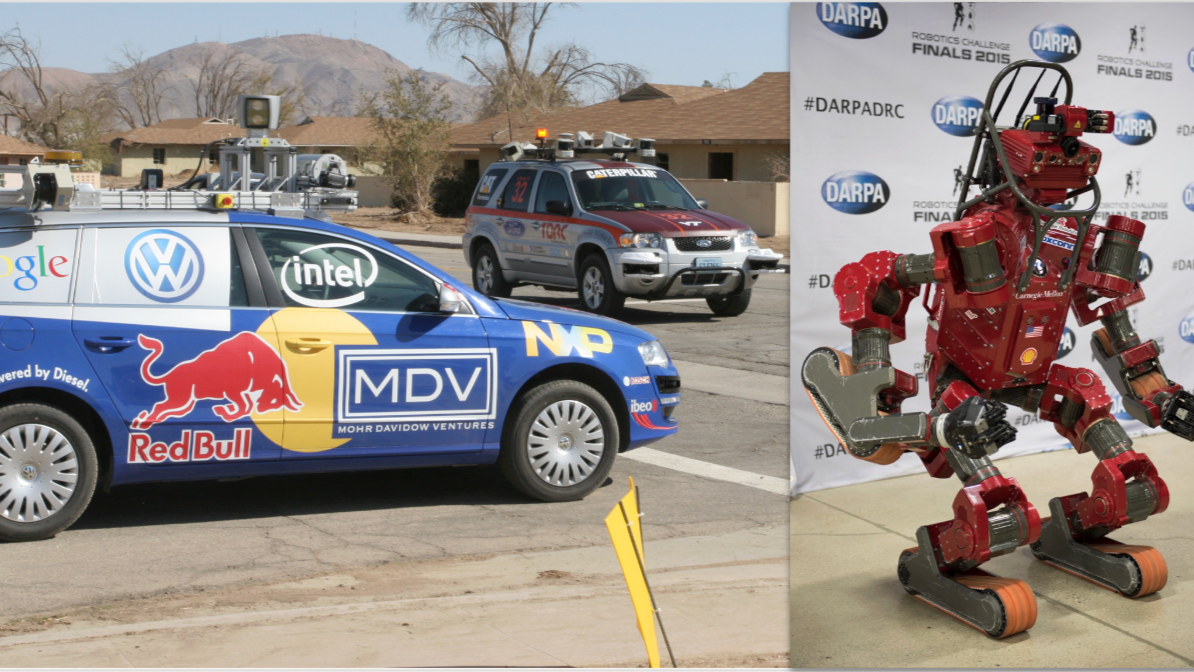
Physical AI: The DARPA Legacy & the Road Ahead — The Parallel Playbook: What Autonomous Driving Can and Can’t Teach Physical AI
The DARPA challenges offer a useful playbook for physical AI. They show how an impressive technical demonstration can help...
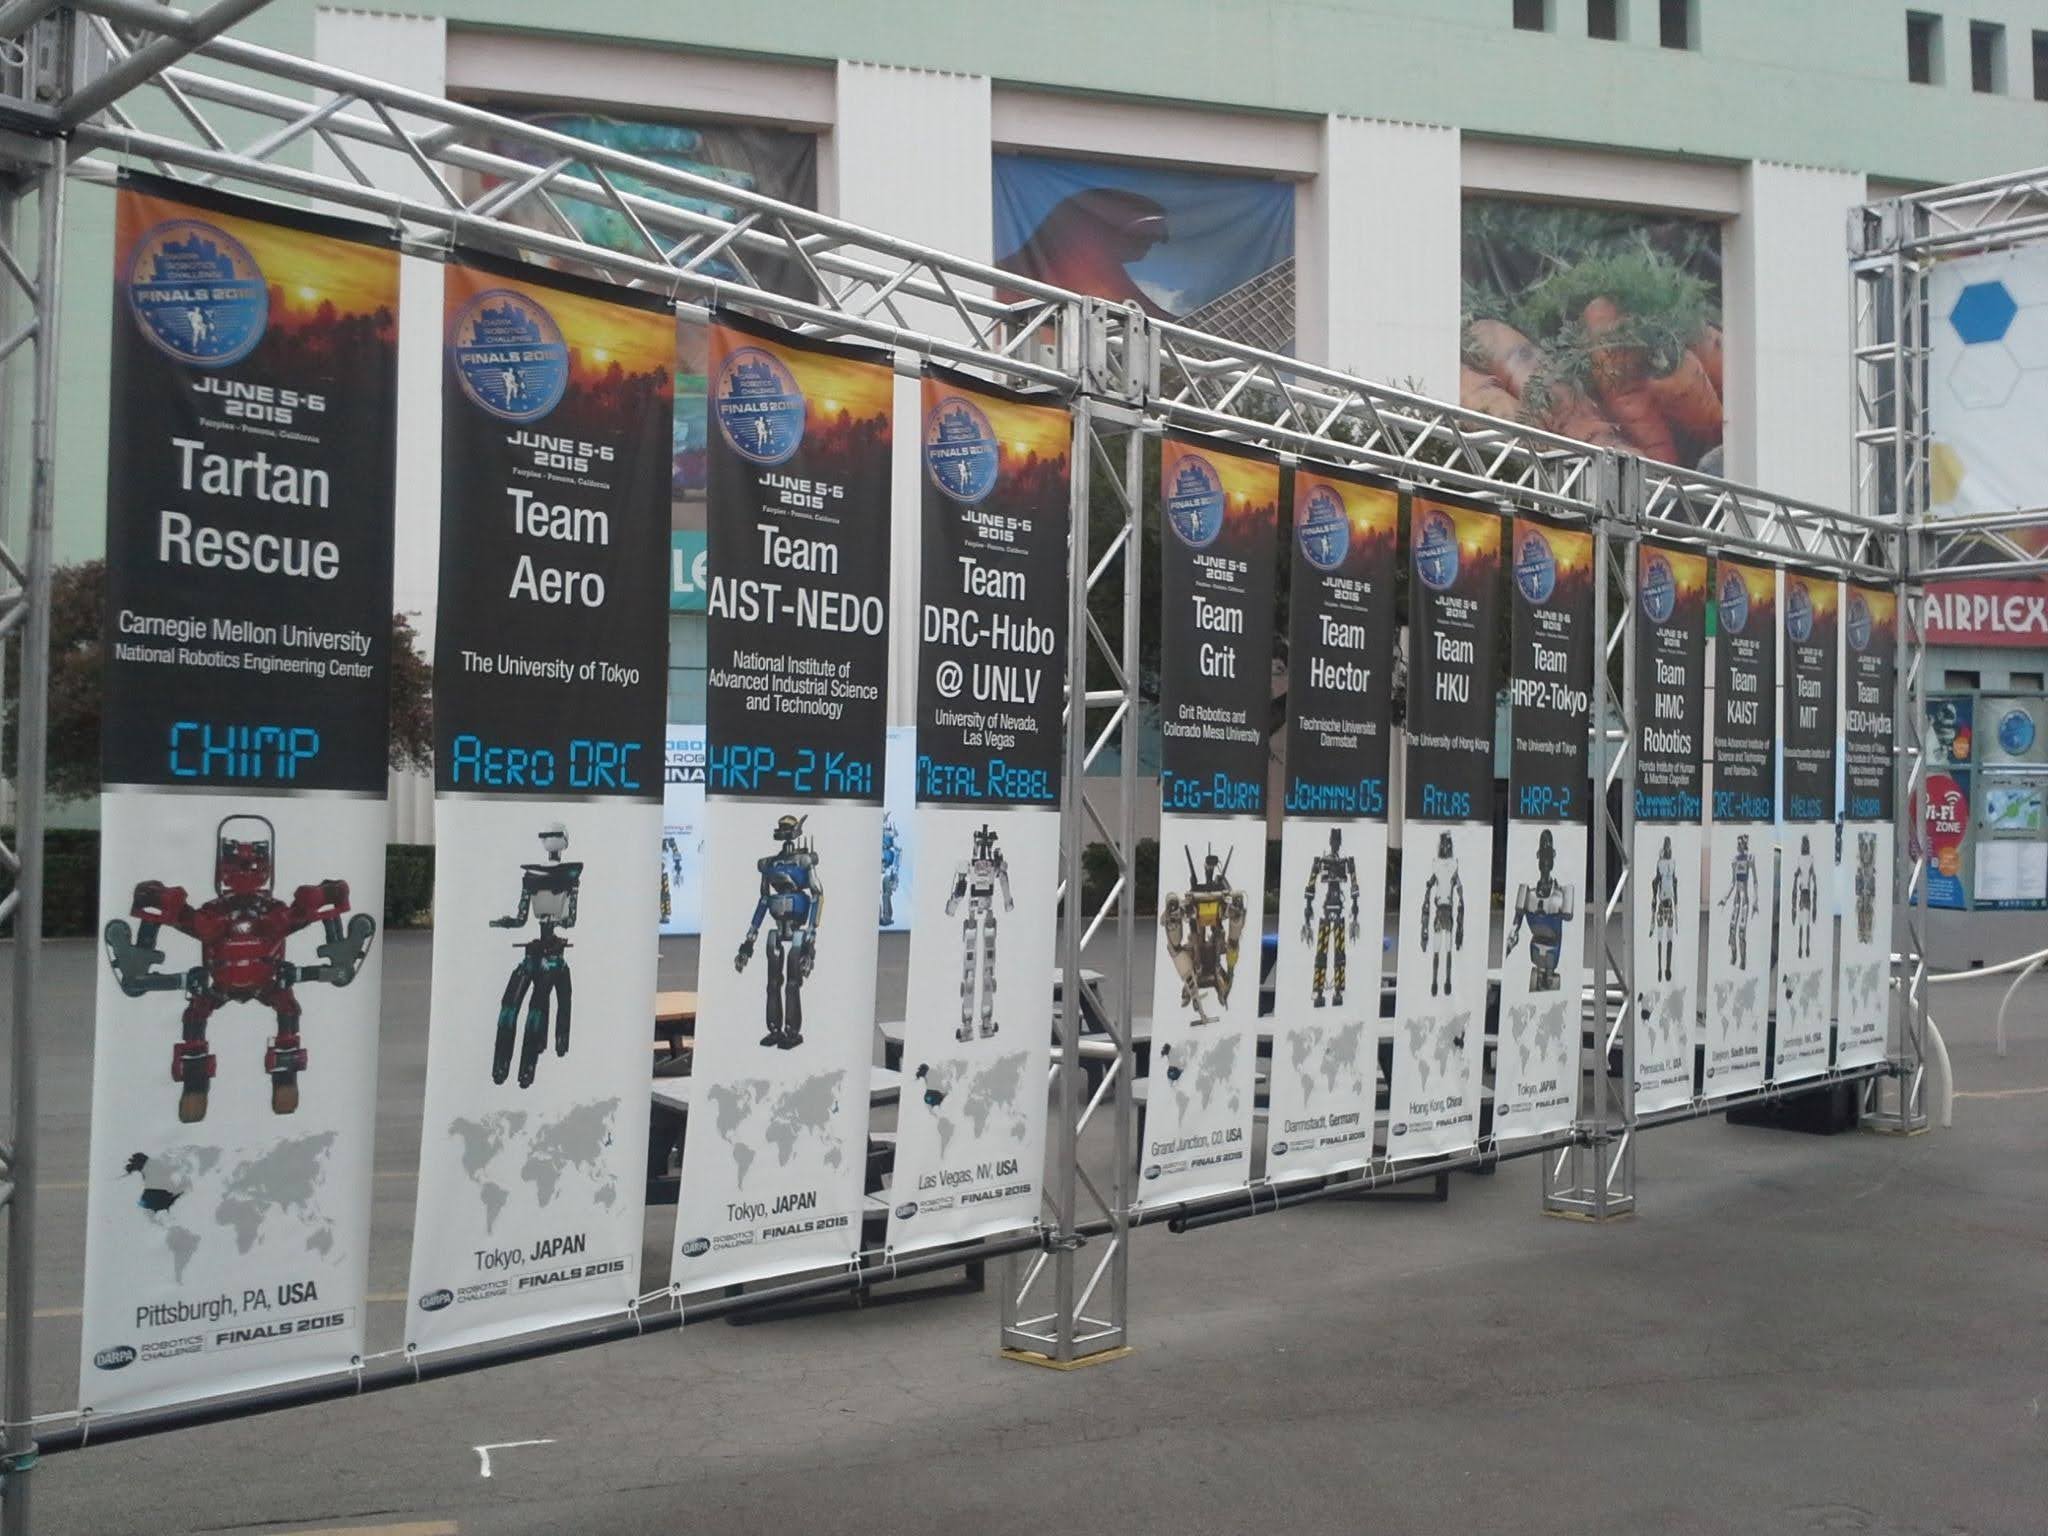
Physical AI: The DARPA Legacy & the Road Ahead — From Face-Plants to Foundation Models
Part 1 of 2, Physical AI: The DARPA Legacy & the Road Ahead. What the DARPA Robotics Challenge Actually Built—and Why It Still...
Leave a comment